
 INTEGRAL TIME (Ti): How Quickly the Integral Action Acts!

In a PID controller, Integral Time (Ti) is a key tuning parameter that determines the strength of the integral action.
It tells us how quickly the integral term responds to a persistent error.
 What is Integral Time?
Integral Time (Ti), also called Reset Time, is the time required for the integral action to produce an output change equal to the proportional action for a constant error, under the standard ISA form of the PID equation.
The integral contribution can be represented as:
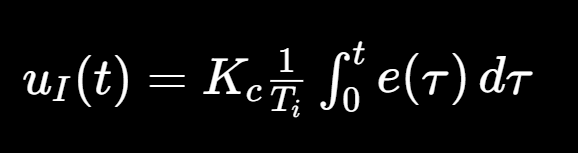
Where:
- Ti = Integral Time
- Kc = Controller gain
- e(t) = Error = SP − PV
- uI = Integral contribution
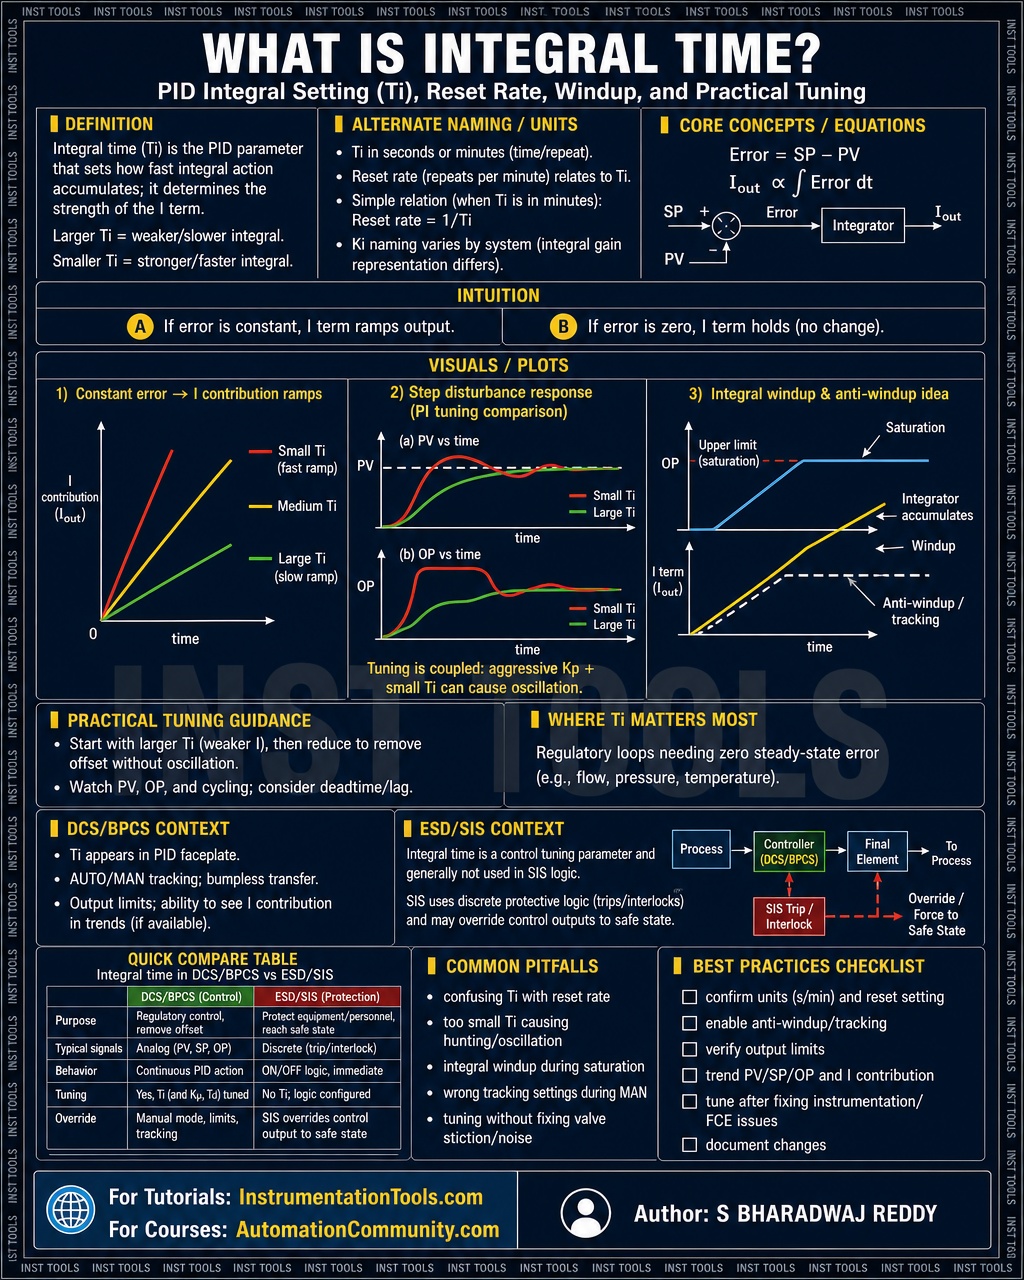
 The Most Important Relationship
Smaller Ti → Stronger/Faster Integral Action
Larger Ti → Weaker/Slower Integral Action
Think of it like this:
Ti = 2 min
 Integral action is relatively strong
Persistent error is corrected faster
Ti = 10 min
Integral action is weaker
Correction occurs more slowly
 Example
Suppose a flow controller has:
 SP = 100 m³/h
 PV = 90 m³/h
There is a persistent error of:
10 m³/h
The proportional action responds immediately.
The integral action keeps accumulating this error over time and continues adjusting the controller output until the steady-state error is eliminated.
If Ti is reduced, the integral action becomes more aggressive.
If Ti is increased, the integral action becomes less aggressive.
 What Happens if Ti is Too Small?
The integral action becomes very aggressive.
This can cause:
 Overshoot
Oscillation
Poor stability
Integral windup problems when the output saturates
What Happens if Ti is Too Large?
The integral action becomes too slow.
You may see:
Slow elimination of offset
Sluggish response to disturbances
Longer time to reach the setpoint
Integral Time vs Integral Gain
These are often confused.
Integral Gain (Ki):
Higher Ki → stronger integral action.
Integral Time (Ti):
Smaller Ti → stronger integral action.
For the common ISA/ideal PID form:
Ki = Kc / Ti
So they are inversely related.
 Easy Way to Remember
 Ti = Reset Time
Small Ti = Fast Reset 
Large Ti = Slow Reset 
And remember:
#IntegralTime #ResetTime #PID #PIDControl #ControlSystems #ProcessControl #Instrumentation dcs #PLC Automation #ControlEngineering #IndustrialAutomation #InstrumentationEngineer