
 INTEGRAL WINDUP: When the Integral Term Keeps Building Up!

In a PID controller, the Integral (I) action continuously accumulates the error between the Setpoint (SP) and Process Variable (PV).
That is useful for eliminating steady-state error—but it can create a serious problem when the controller output reaches its limit.
 What is Integral Windup?
Integral windup occurs when the integral term continues accumulating error while the controller output is already at its maximum or minimum limit.
In simple words:
The controller wants to increase/decrease its output, but the output cannot go any further—while the integral keeps accumulating.
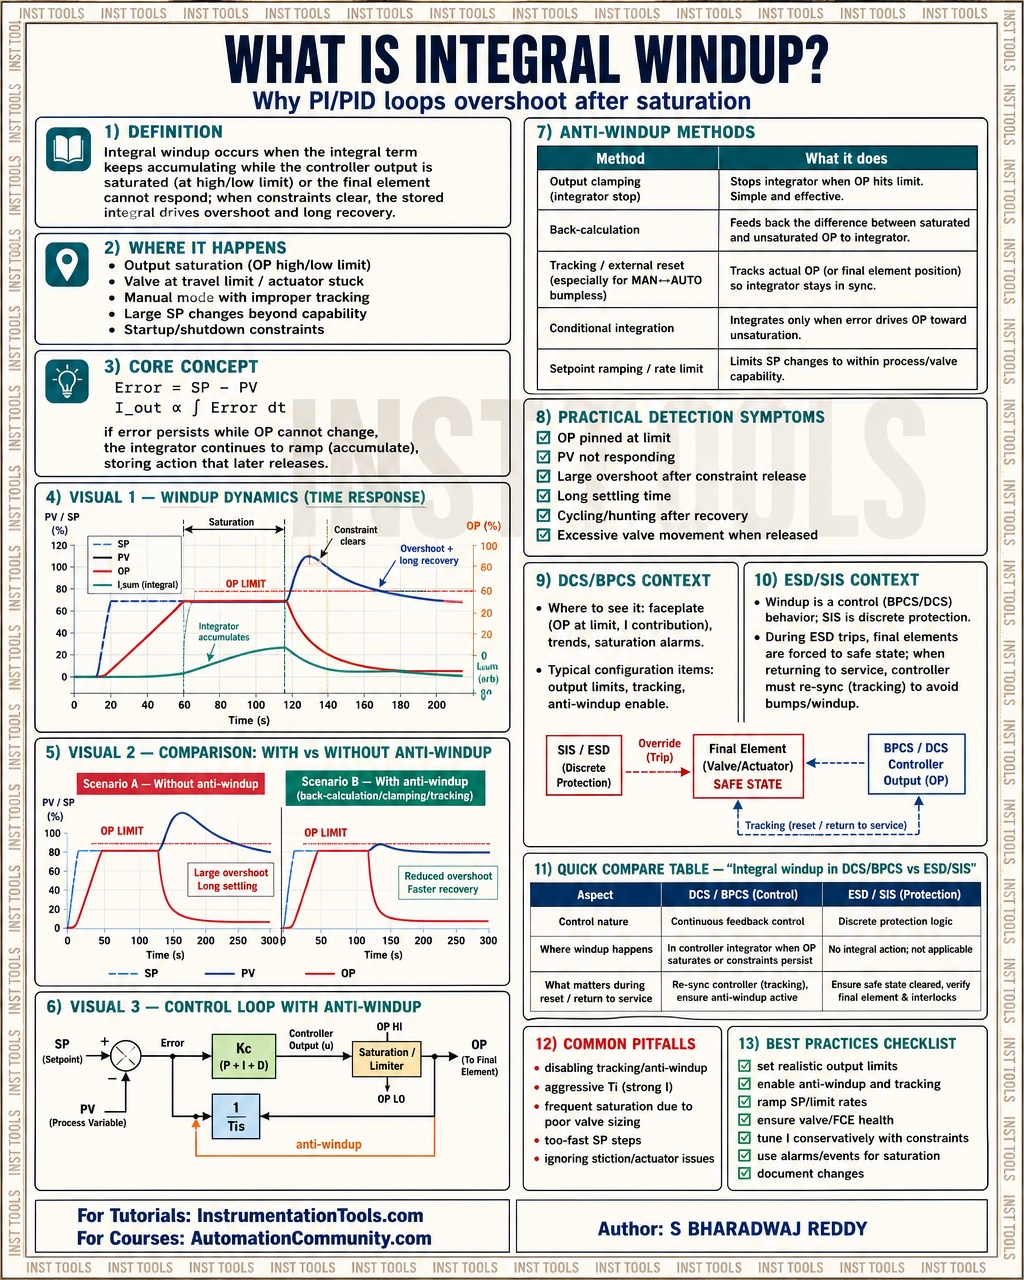
 Example: Control Valve
Suppose a temperature controller is controlling a heater.
Setpoint = 100°C
 Actual temperature = 70°C
The controller sees a large error and increases its output:
60% → 80% → 100%
But the output limit is:
 Maximum = 100%
The temperature still remains below 100°C because the heater has insufficient capacity.
However, the integral term continues accumulating the error.
 This is integral windup.
 What Happens When the Process Recovers?
Eventually, the temperature starts increasing.
But the integral term has accumulated a large value.
So even when:
PV approaches SP
the controller may still command a very high output.
Temperature can overshoot significantly.
The controller then takes a long time to recover.
This can cause:
 Large overshoot
Slow recovery
Oscillation
Poor control performance
Unnecessary process disturbances
 Typical Sequence
Large error

Integral accumulates
Controller output reaches 100%
Output cannot increase further
Integral continues accumulating
Process eventually approaches SP
Excess integral remains
Output stays too high
Overshoot
 How Do We Prevent Integral Windup?
Common anti-windup techniques include:
 Integral clamping
Limits the integral term when the output reaches its limits.
Conditional integration
Stops or limits integration under appropriate saturation conditions.
Back-calculation
Adjusts the integral state based on the difference between the demanded and actual limited output.
Output limiting with proper anti-windup configuration
Interview Question
What is integral windup in a PID controller?
 Integral windup occurs when the controller output is saturated at its limit while the integral action continues accumulating error, causing excessive integral action and potentially large overshoot when the process returns toward the setpoint.
 Remember:
Output saturated + Integral keeps accumulating = Integral Windup
#IntegralWindup #PID #PIDControl #ControlSystems #ProcessControl #Instrumentation dcs #PLC Automation #ControlEngineering #IndustrialAutomation #ProcessControl #InstrumentationEngineer #AutomationEngineer