
 INTEGRAL CONTROL: The Control Action That Eliminates Steady-State Error!

Imagine a temperature controller with:
Setpoint = 100°C
 PV = 95°C
The controller has a 5°C error.
Proportional action responds immediately, but depending on the process and controller, a small error may remain.
 Integral control keeps acting as long as the error persists.
 What is Integral Control?
Integral control is a control action in which the controller output is continuously adjusted according to the accumulated error over time.
In simple words:
The longer the error exists, the more integral action builds up.
The integral term is based on the accumulated error:
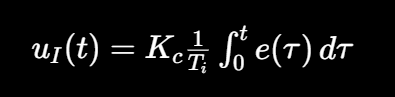
Where:
- e(t) = Error = SP − PV
- Kc = Controller gain
- Ti = Integral time
- uI = Integral contribution
 Example: Flow Control
Suppose:
SP = 100 m³/h
 PV = 90 m³/h
Error = 10 m³/h
The integral controller sees that the error continues to exist and keeps increasing its output.
For example:
Valve output:
40% → 45% → 52% → 60% → 68% …
As the flow approaches the setpoint, the error becomes smaller.
Eventually:
SP ≈ PV
 Steady-state error is eliminated.
 Key Characteristic of Integral Control
The important point is:
Integral action depends on both the magnitude AND duration of the error.
A small error that exists for a long time can produce significant integral action.
For example:
Large error for short time → Moderate accumulation
Small error for long time → Significant accumulation
Main Advantage
 Eliminates steady-state offset
This is why integral action is widely used in:
Temperature control
 Level control
 Flow control
Pressure control
Process control
 Disadvantages
If integral action is too aggressive, it can cause:
 Overshoot
Oscillation
Slow recovery
Integral windup when the controller output saturates
Therefore, Integral Time (Ti) must be tuned appropriately.
Remember:
 Small Ti → Stronger integral action
Large Ti → Weaker integral action
 Proportional vs Integral
Proportional Control:
Responds to the present error.
Integral Control:
Responds to the accumulated past error.
A simple way to remember:
P asks: “How big is the error now?”
I asks: “How long has the error been present?”
 Interview Question
Why is integral control used in a PID controller?
Integral control is used primarily to eliminate steady-state error (offset) by continuously accumulating the error and adjusting the controller output.
 But remember: Integral action is powerful—if poorly tuned or allowed to wind up during output saturation, it can seriously degrade control performance.
#IntegralControl #PID #PIDControl #ControlSystems #ProcessControl #Instrumentation dcs #PLC Automation #ControlEngineering #IndustrialAutomation #IntegralAction #ProcessControl #InstrumentationEngineer